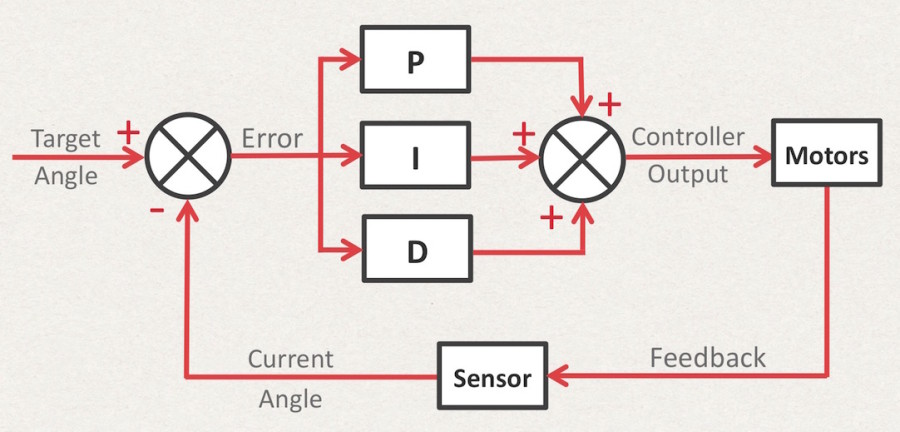
The PID Controller
The most important element of any robot is the controller. The control algorithm determines how the robot should react to different sensor inputs, allowing it to intelligently adapt to and interact with…
In this part of the tutorial I will cover how to get the most performance out of the MPU-6050 Accelerometer and Gyroscope module, using the "Motion Apps" library. This library is really amazing…
A lithium quad-copter battery, powering a Galileo Gen2 Board How to connect a battery to the Arduino When working with sensitive circuits and micro-controllers, batteries can be a tricky thing to get…
If you haven't already read the first part of this Self-balancing robot series, I would encourage you to do so now! The first section below deals with a little bit of theory…
Why build a self-balancing robot? The aim of a self-balancing robot is to balance itself on two wheels, being able to drive around without toppling over. Self-balancing robots use a "closed-loop feedback…